Development of SML Sampler

The InterSeA research group designed an automated SML sampler, assuring a convenient sampling process, permitting high sample volumes within a reasonable time scale, allowing for research in broad and numerous sites.

The principles of the SML sampler design are based on the significant

a) restriction of sampling duration (less than 1 h),
b) labor restriction of the personnel participating in the SML sampling process and
c) volume increase of SML samples collected.

The automated and easily applicable sampler is designed in order to assure representative collection of an adequate amount of SML sample, of thicknesses less than 60 μm, within a reasonable time scale and minimizing potential contamination of the samples.
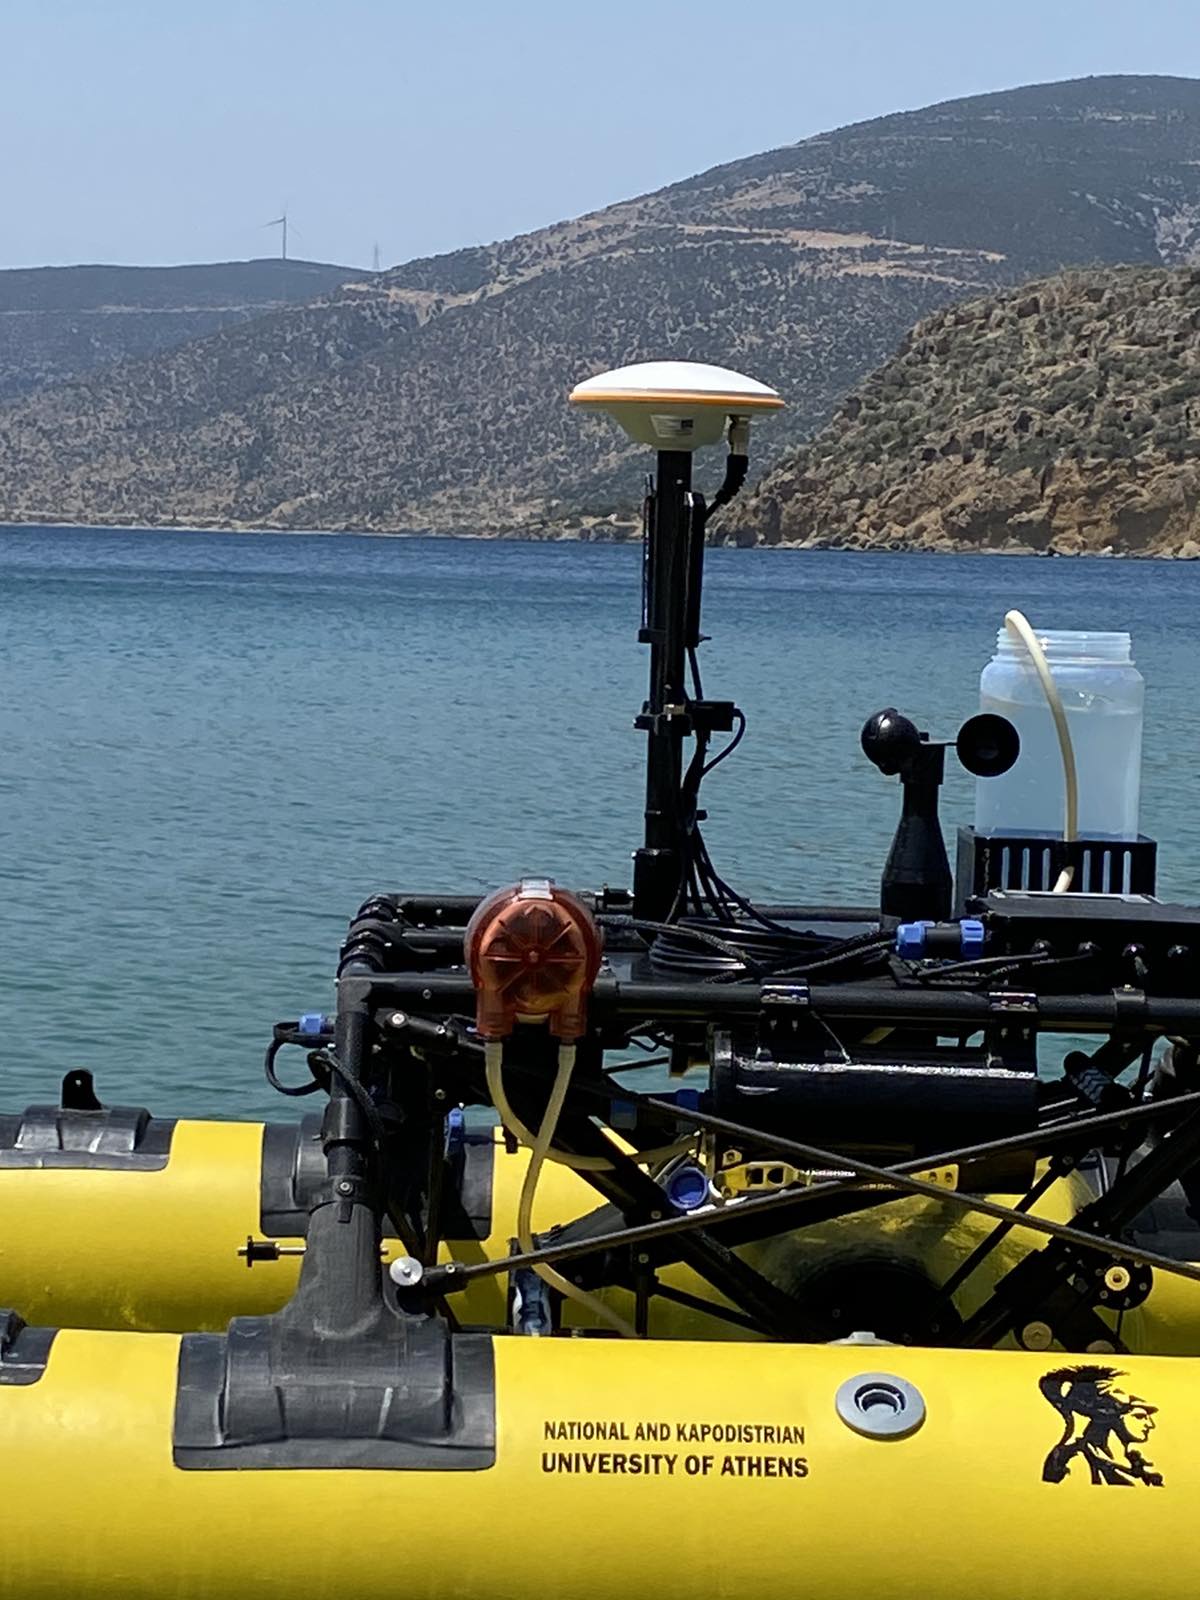
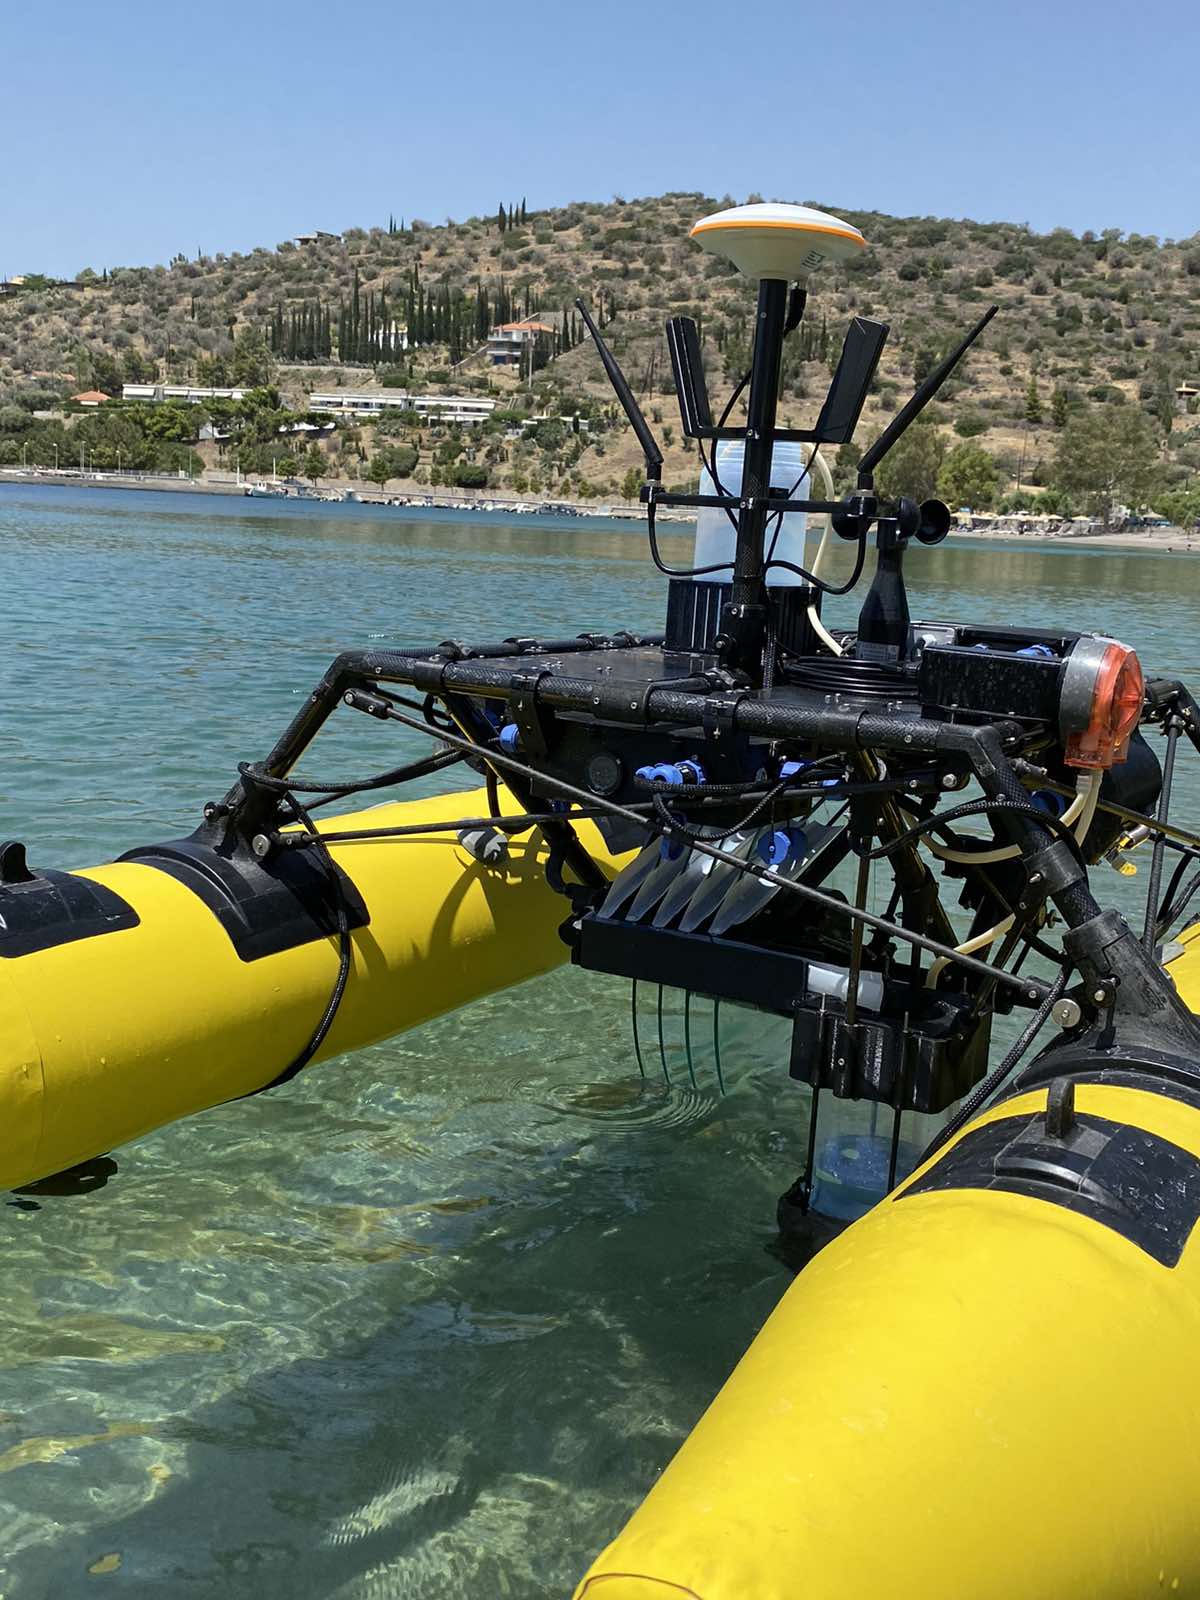
The SML sampler consists of a set of four (4) parallel circular glass disks, vertically immersed approximately by one third into the water and slowly rotated by an electric motor against the direction of motion across the water surface.

The microlayer film adhering onto the ascending side of each rotating disk is subsequently collected by a sharp, inclined Teflon wiper, placed at the downward side of the sampler, leading the water to flow into a precleaned container.

Also, a peristaltic pump is adapted to one side of the USV in order to collect subsurface water from an approximate depth of 20 cm from the surface. The sample is driven through two pipes into a precleaned container on top of the vessel.

The samplers for SML and subsurface water collection are installed on an Unmanned Surface Vehicle (USV) of catamaran type, constructed in Greece, with the capacity of assembly and disassembly in individual parts.

It operates in various ways, possessing several features, the selection and combination of which is made by each user and according to a specific application:

  • Autonomous (mission accomplishment) or manual operation
  • Navigation (remote) through joystick or ground station (laptop)
  • Elaboration of programmed or manual sampling procedures
  • Display of real time data or on site data logging

The USV system comprises distinct ground and floating sections, consisting of different parts.

The floating part includes:

  • The main USV vessel, including the mechanical parts (frame, deck, motor, batteries, basic electronic systems of navigation and control)
  • The GPS & Telemetry subsystem for USV navigation, data georeference and remote vessel navigation
  • Additional equipment (payload) comprising:
    – Sensor for wind speed calculation
    – Sensor for solar irradiation calculation
    – Sub system for water collection employing a peristaltic pump
    – Sub system for SML collection employing the discs set

The ground part includes:

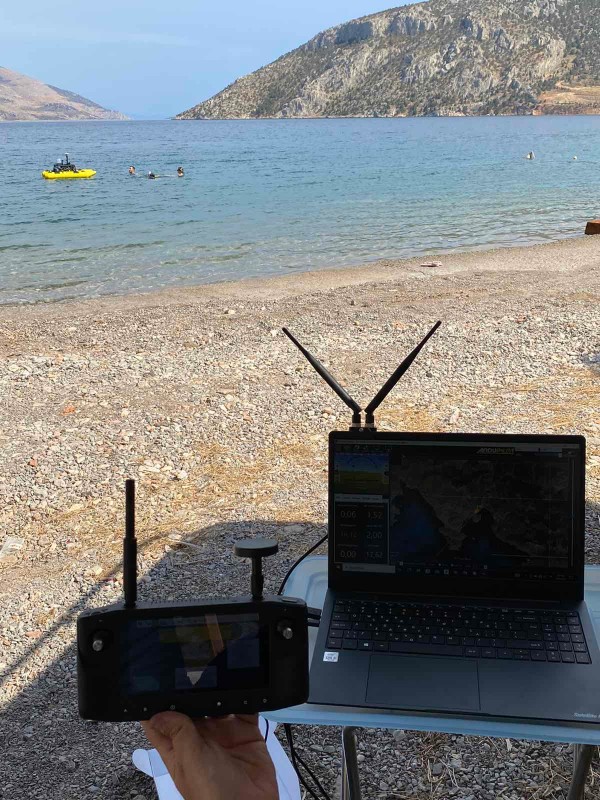
  • The remote control joystick/tablet (HERELINK), for USV navigation and telemetry (transfer of data on USV operation). A real time video, recorded by the camera, included in the basic equipment of the USV, is available to the user on the tablet screen.
  • The ground station (laptop)
    – Running the software Mission Planner, for controlling all parameters of USV operation and defining autonomous missions
    – Displaying real time data by wind and solar irradiation sensors
    – Displaying real time messages for the operation of the SML sampler and peristaltic pump